Home /Software /ABB RobotStudio

ABB RobotStudio Engineering Projects

Explore robotic digital-twin, motion-programming, automation optimization and mechanical robotic-arm CAD projects. Hover over a project for a preview, then click to view the workflow.

Twin-Arm Pick & Place
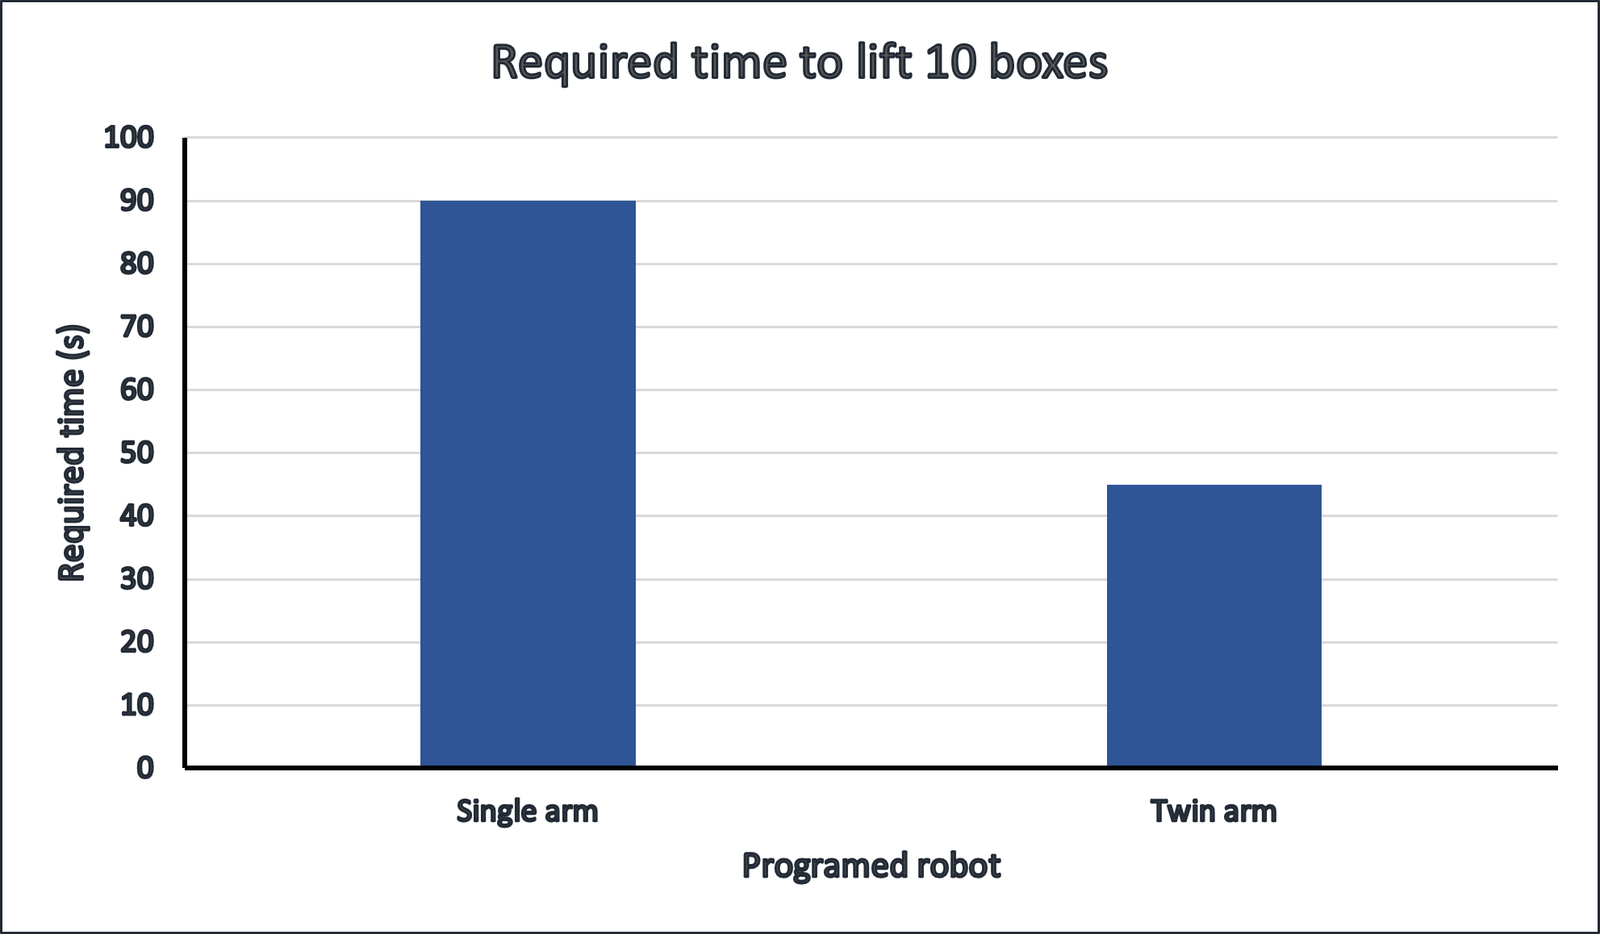
Station Logic & Optimization
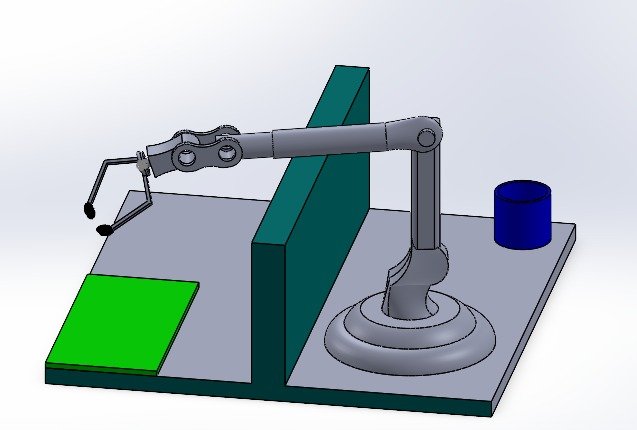
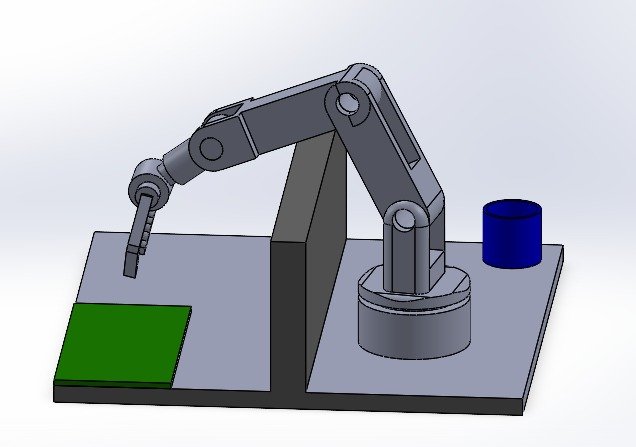
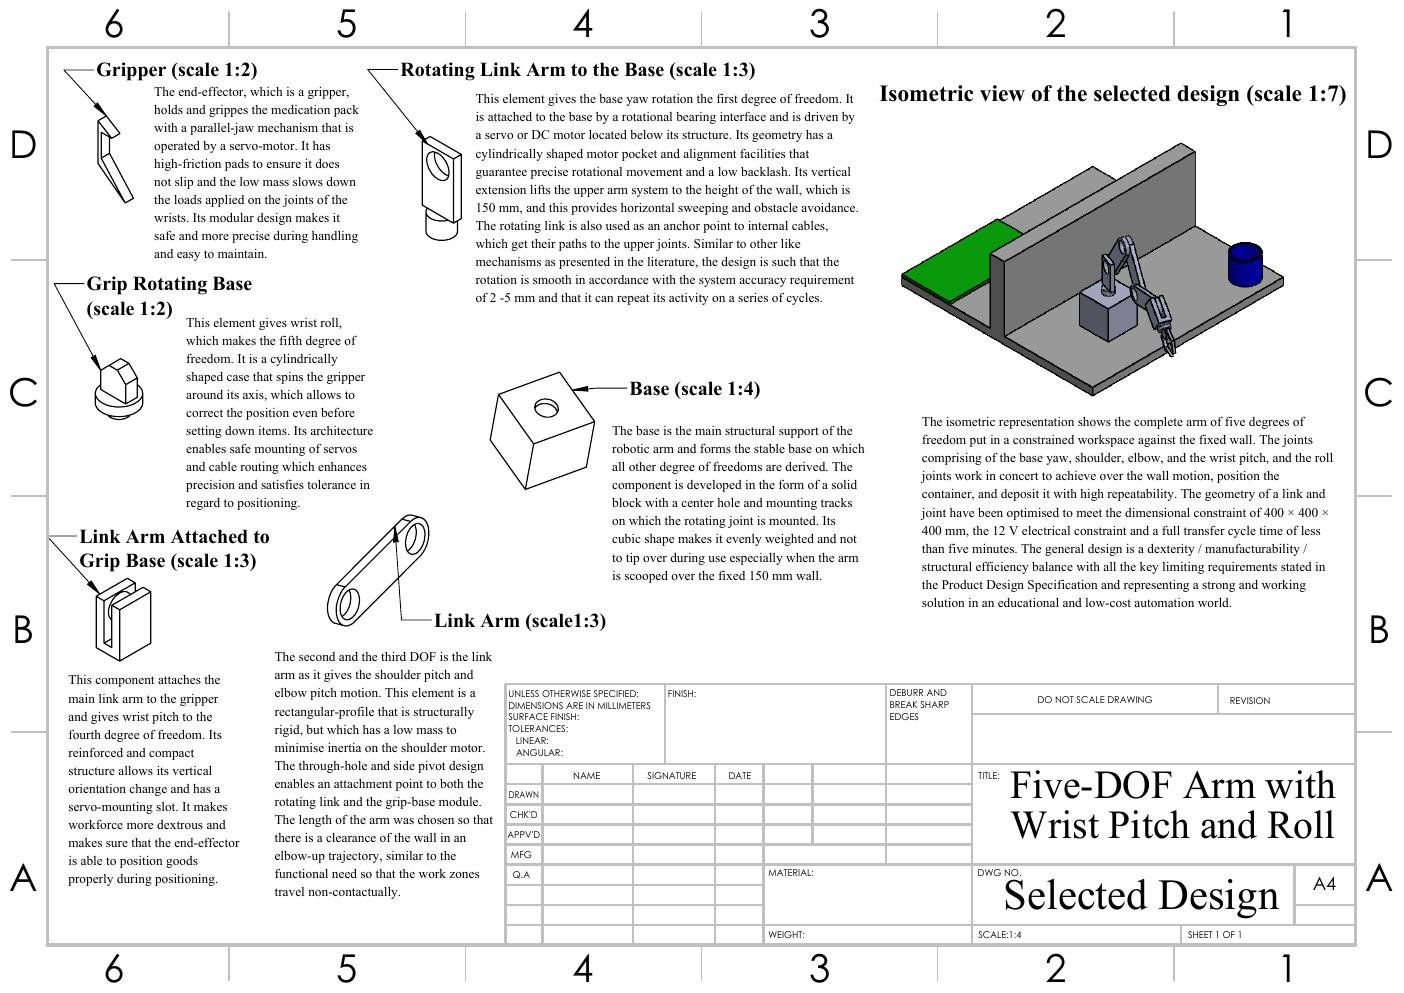
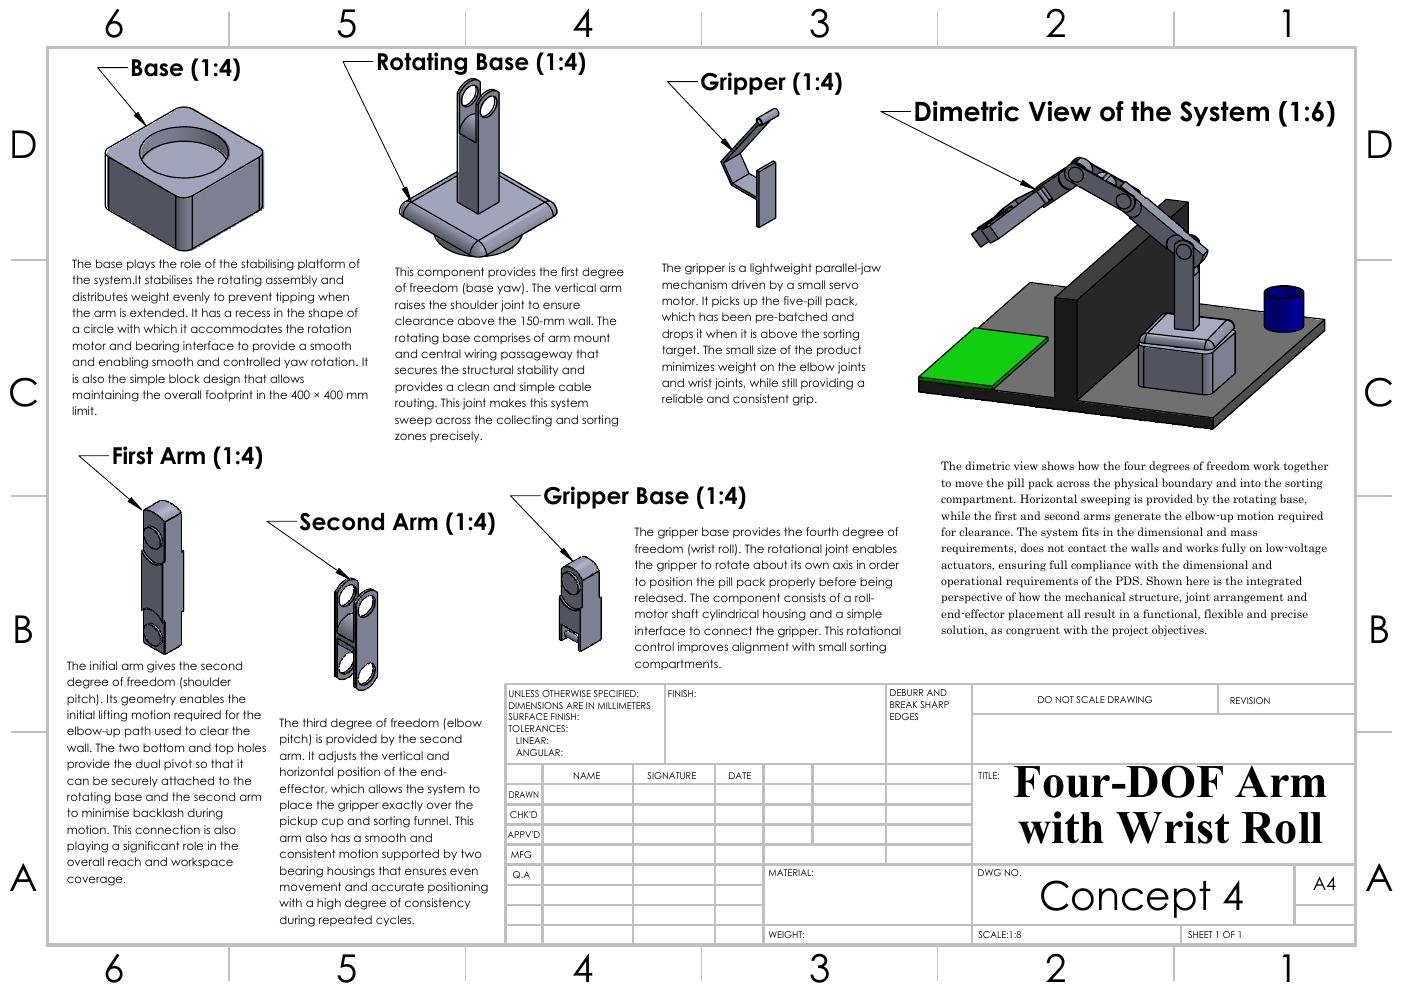
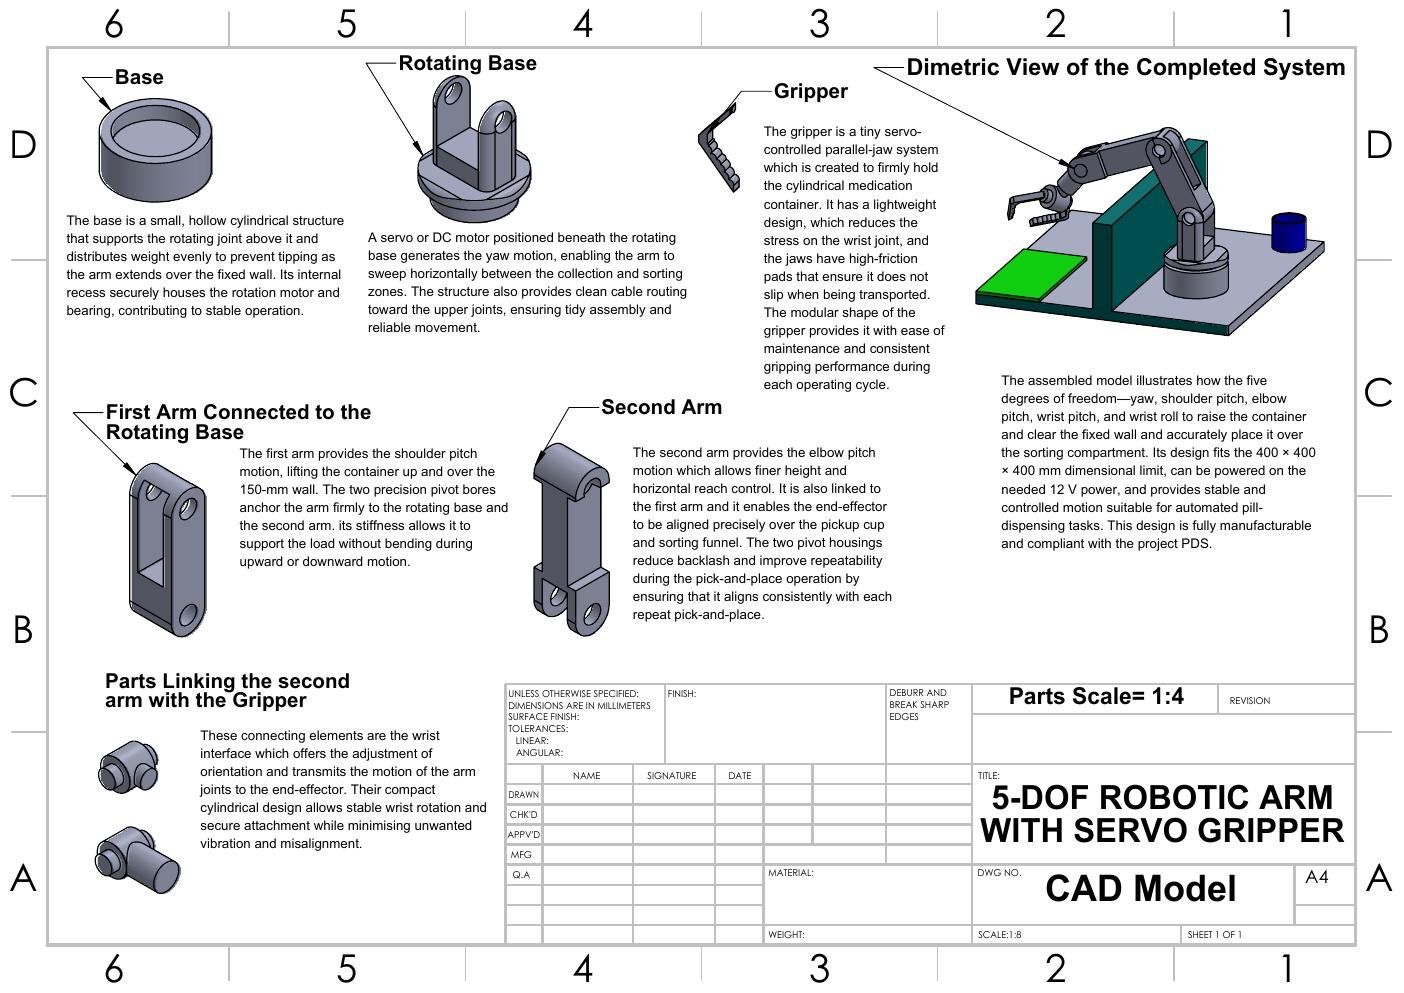
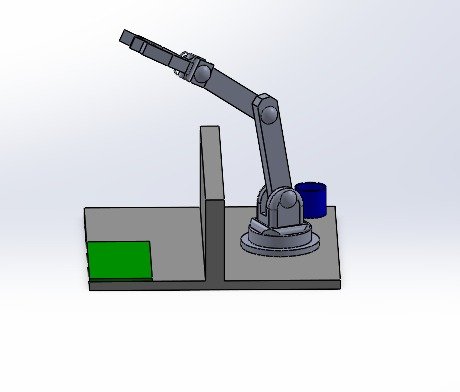
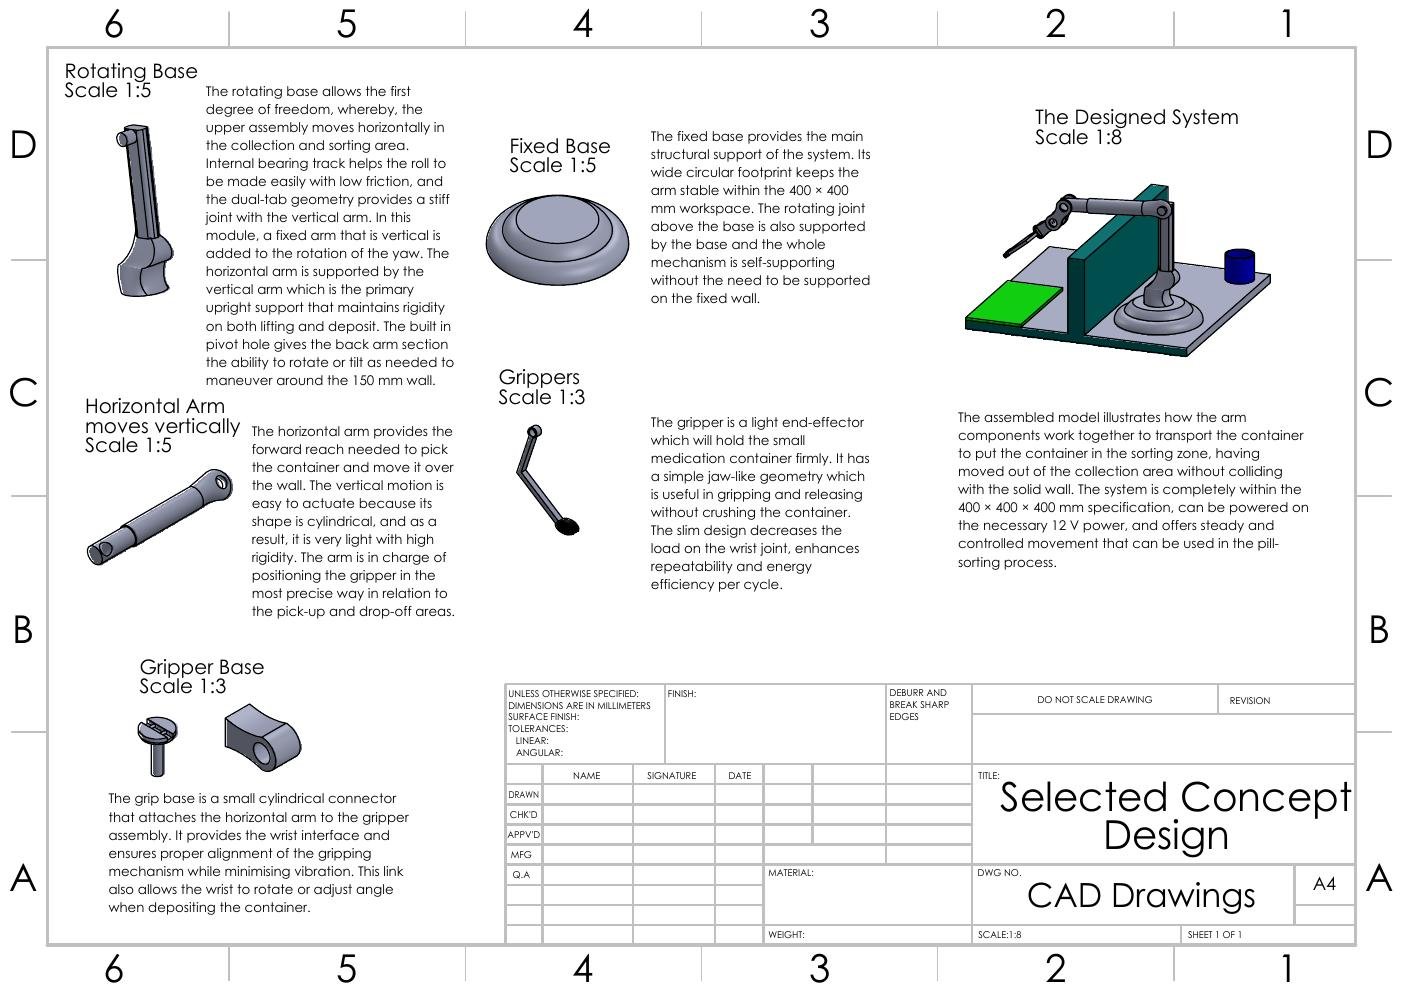
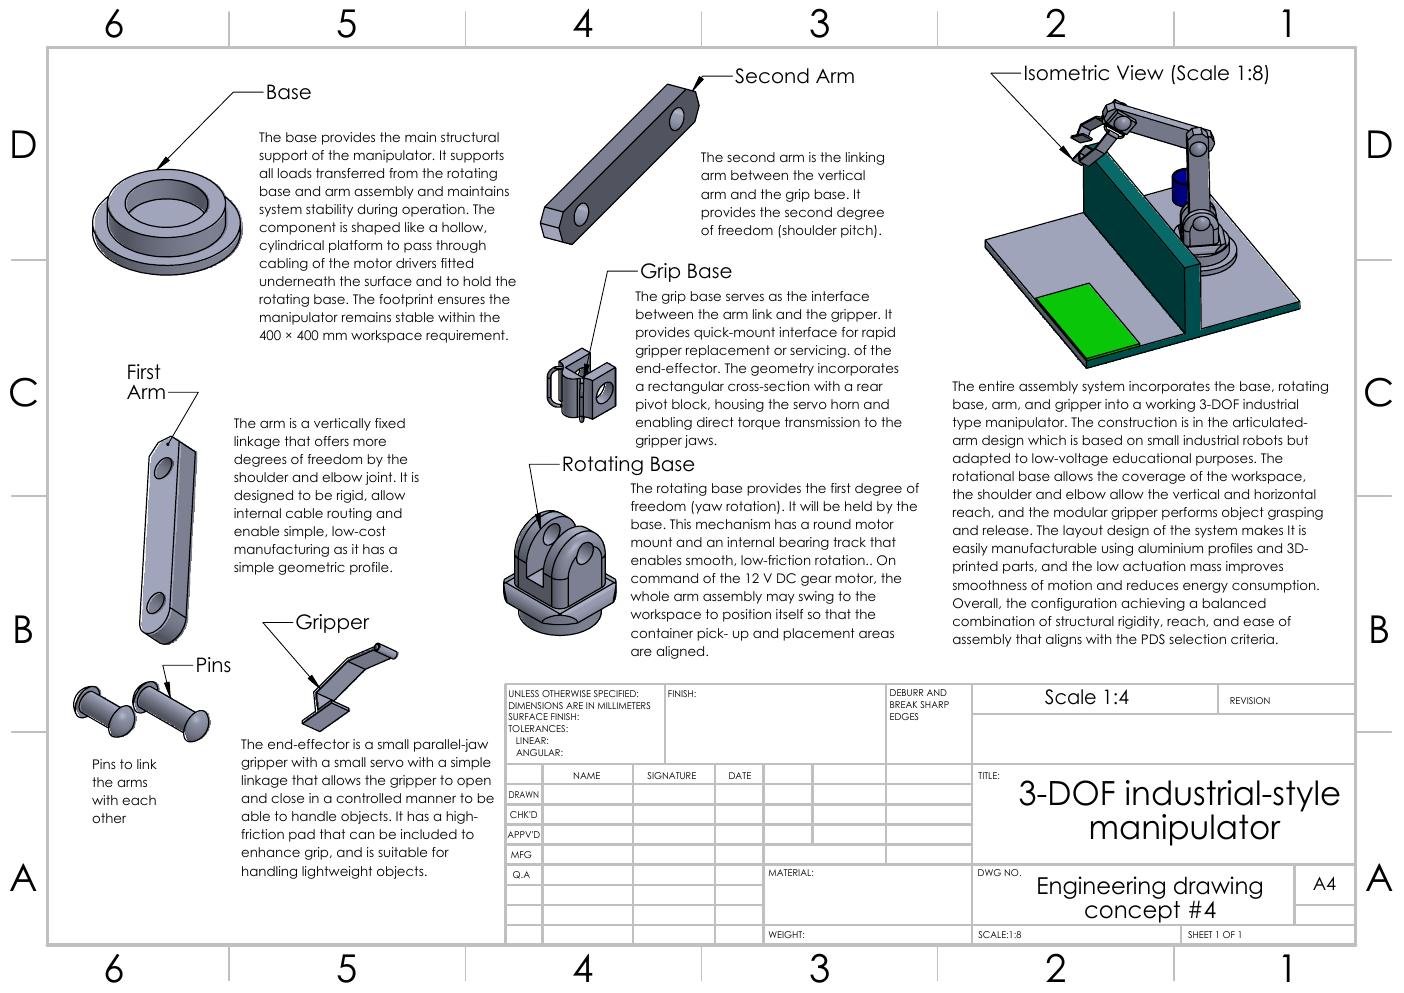
Custom Robotic Arm CAD

Twin-Arm Pick & Place RobotStudio Simulation

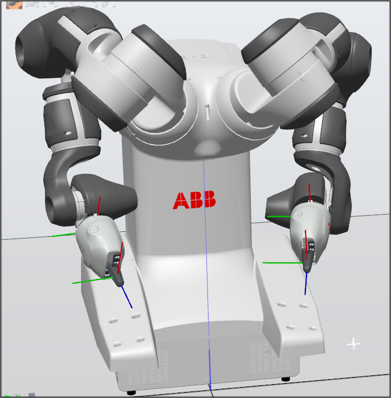
Development of an autonomous pick-and-place digital twin using the ABB IRB 14000 YuMi twin-arm robot. The project builds a complete RobotStudio station for object handling, target programming and realistic motion validation.

ABB RobotStudio YuMi simulation
Step 01

Workstation and Digital Twin Setup

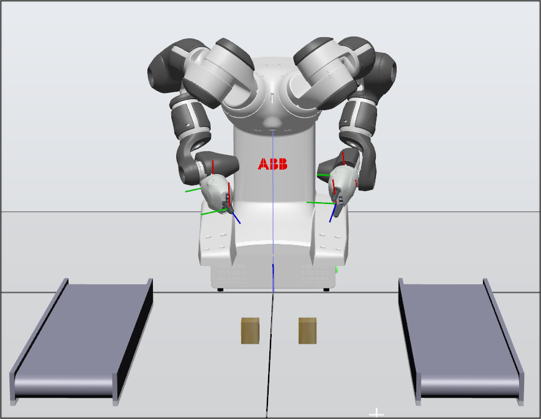
The physical workspace is virtually replicated by importing the ABB YuMi robot, smart grippers, conveyors and target boxes into RobotStudio. This establishes the station layout used for the full automation workflow.

RobotStudio workstation layout
RobotStudio motion path programming
Step 02

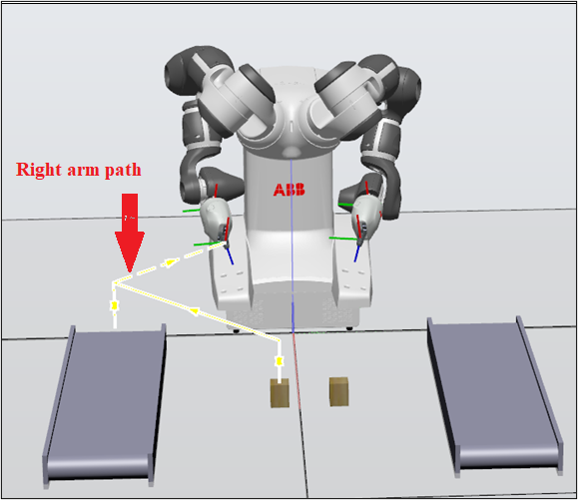
Motion Path and Target Programming

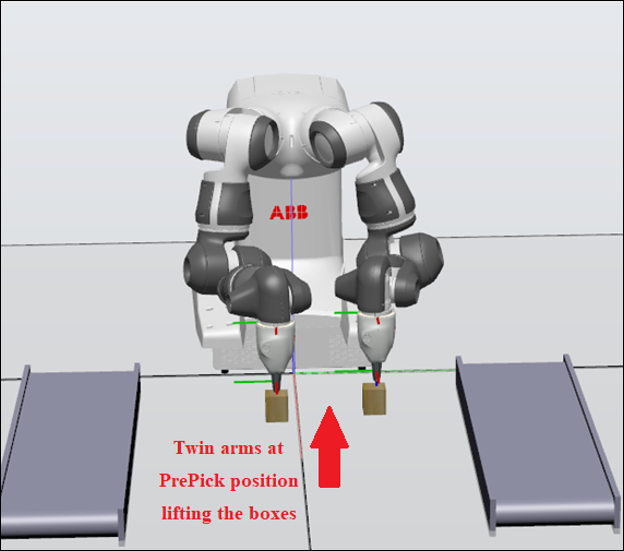
Linear and joint move instructions are used to define target positions such as PrePick, PickBox, PrePlace and PlaceBox, producing a smooth collision-free movement sequence from the home position.

Step 03

Smart Components and Station Logic

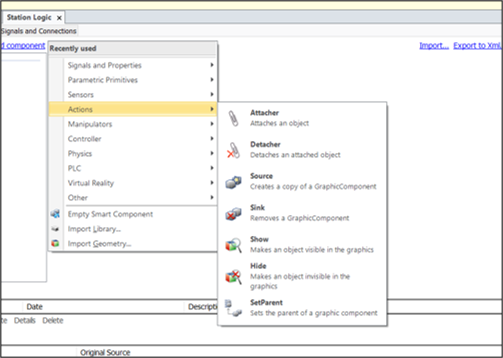
Collision sensors and smart components are configured so the gripper detects the box and triggers attachment and detachment events, giving the digital twin realistic pick-and-place behaviour.

RobotStudio smart components and station logic